Embarking on a do-it-yourself (DIY) robotics project offers more than just a hobby; it provides a tangible pathway for skill acquisition, problem-solving, and practical application of engineering principles. For makers, educators, and even those in product development, these projects translate theoretical knowledge into functional prototypes, building critical proficiencies in electronics, programming, mechanical design, and system integration. The decision to start a robotics project hinges on balancing ambition with current skill sets and available resources, ensuring a rewarding learning curve rather than frustration. This guide outlines various project ideas, categorized by complexity, to help you select an appropriate starting point or next challenge, emphasizing the practical skills each build cultivates.
Starting Simple: Entry-Level Robotics Projects
Beginner projects focus on fundamental concepts, providing a solid foundation without requiring extensive prior knowledge. These builds are ideal for grasping basic electronics, simple programming logic, and mechanical assembly.
Line-Following Robot
This classic beginner project introduces core concepts of sensor input and motor control. The robot uses infrared (IR) sensors to detect a dark line on a light surface, then adjusts its motors to stay on course. It’s an excellent entry point for understanding feedback loops and conditional programming.
Key Skills Developed:
- Basic circuit building (connecting sensors, motors, microcontroller)
- Microcontroller programming (e.g., Arduino C++) for sensor reading and motor actuation
- Understanding digital and analog signals
- Calibrating sensors for optimal performance
Typical Components: Microcontroller board (e.g., Arduino Uno), IR line-following sensors, DC motors, motor driver module, chassis, wheels, power source.
Obstacle-Avoiding Robot
Building on line-following principles, an obstacle-avoiding robot introduces the concept of environmental awareness and decision-making. Using an ultrasonic sensor, the robot detects objects in its path and alters its trajectory to bypass them. This project reinforces sensor integration and introduces more complex conditional logic.
Key Skills Developed:
- Integrating range-finding sensors (ultrasonic)
- Implementing decision trees in code (if/else statements based on distance)
- Basic navigation algorithms
- Troubleshooting sensor readings and motor responses
Typical Components: Microcontroller board, ultrasonic sensor, servo motor (for sensor panning, optional), DC motors, motor driver, chassis, wheels, power source.
Intermediate Challenges: Expanding Capabilities
Once comfortable with basic builds, intermediate projects introduce more complex mechanical systems, advanced sensor integration, and refined programming techniques. These projects often require a deeper understanding of kinematics, control theory, and communication protocols.
Robotic Arm with Gripper
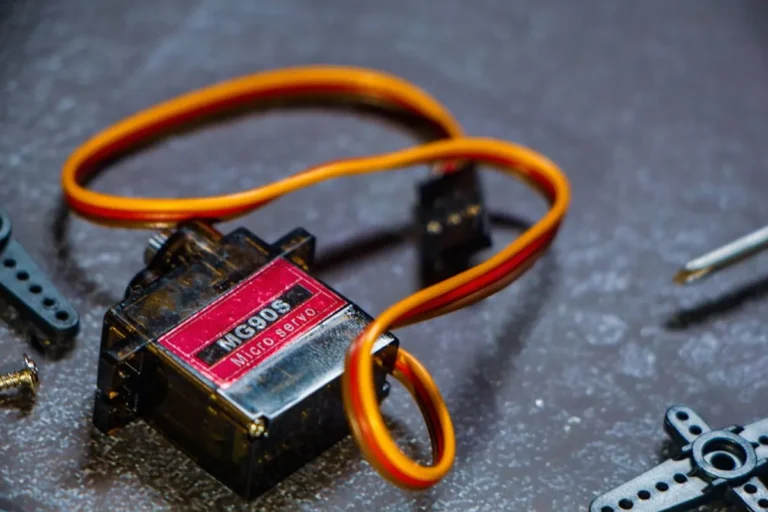
A robotic arm project involves precise control over multiple servo motors to mimic human arm movements. This build often focuses on inverse kinematics (calculating joint angles to reach a specific point) and developing user interfaces for control, such as joysticks or graphical applications. It offers practical experience in mechanical design and multi-axis control.
Key Skills Developed:
- Multi-servo motor control and synchronization
- Understanding degrees of freedom and mechanical linkages
- Implementing inverse kinematics (for advanced control)
- Developing user input methods (joystick, potentiometers, GUI)
- Precision mechanical assembly
Typical Components: Multiple servo motors (3-6), microcontroller board, custom or pre-fabricated arm structure, gripper mechanism, power supply, control interface (joystick, buttons).
Home Automation Assistant
This project merges robotics with smart home technology, creating a device that can interact with its environment to perform tasks like monitoring temperature, controlling lights, or even serving as a simple security system. It emphasizes network communication, data processing, and integration with other smart devices or platforms.
Key Skills Developed:
- Wireless communication (Wi-Fi, Bluetooth, Zigbee)
- Interfacing with various sensors (temperature, humidity, light) and actuators (relays, smart plugs)
- Developing web interfaces or mobile app control
- Data logging and analysis
- Understanding Internet of Things (IoT) principles
Typical Components: ESP32/ESP8266 microcontroller, various sensors (DHT11, LDR), relays, small display, power supply, enclosure.
Pro Tip: When sourcing components for DIY robot projects, prioritize modularity and widely supported development platforms. Opting for components with clear documentation and active community forums can significantly reduce troubleshooting time and accelerate your learning process, especially for complex integrations.
Advanced Builds: Integrating Complex Systems
Advanced projects challenge makers to combine multiple subsystems, integrate sophisticated sensors, and develop more robust software architectures. These often involve artificial intelligence, machine vision, and real-time operating systems, preparing individuals for complex engineering challenges.
Autonomous Rover with Vision
An autonomous rover with vision capabilities involves equipping a mobile robot with a camera and processing unit to interpret its surroundings. This project delves into computer vision algorithms for object detection, navigation, and mapping (SLAM – Simultaneous Localization and Mapping). It's a significant step towards understanding self-driving technologies and advanced perception systems.
Key Skills Developed:
- Computer vision fundamentals (OpenCV, image processing)
- Integrating single-board computers (e.g., Raspberry Pi) with microcontrollers
- Implementing navigation and path planning algorithms
- Real-time data processing and decision-making
- Understanding sensor fusion (combining camera data with IMU, encoders)
Typical Components: Raspberry Pi or similar SBC, camera module, microcontroller, motor drivers, DC motors, encoders, IMU (Inertial Measurement Unit), LiDAR or depth camera (optional), power system, robust chassis.
Humanoid Robot Companion
Building a humanoid robot is a multifaceted challenge, encompassing complex mechanical design, advanced servo control, and sophisticated software for balance, gait, and interaction. This project often involves high-degree-of-freedom kinematics, voice recognition, and potentially even natural language processing. It represents the pinnacle of integrated robotics, blending mechanics, electronics, and AI.
Key Skills Developed:
- Advanced mechanical design and 3D printing for structural components
- High-DOF servo control and inverse kinematics for bipedal locomotion
- Speech recognition and synthesis
- Implementing state machines for complex behaviors
- Understanding human-robot interaction principles
Typical Components: Numerous high-torque servo motors, single-board computer, microcontroller, custom 3D-printed or machined parts, IMU, microphone, speaker, camera, power management system.
Component Considerations and Skill Development
Regardless of the project chosen, the selection of components directly impacts complexity and capability. Microcontrollers like Arduino are excellent for beginners due to their simplicity and extensive community support. For more complex processing, single-board computers such as the Raspberry Pi offer Linux-based environments, allowing for advanced programming languages and computer vision libraries. Focusing on projects that incrementally build skills—from basic I/O to sensor integration, then to complex algorithms and networked systems—ensures continuous learning and practical mastery.
Selecting Your Next Robotics Endeavor
When deciding on your next robotics project, consider your current skill level, the time commitment you can realistically make, and the specific areas of robotics you wish to explore. If your goal is to understand basic control systems, a line-follower is ideal. If you aim to delve into computer vision or AI, an autonomous rover offers a direct path. Each project, regardless of its scale, contributes to a practical understanding of engineering disciplines, fostering innovation and problem-solving abilities vital in technical fields.
Frequently Asked Questions About DIY Robotics
What is the best microcontroller for a beginner robot project?
The Arduino Uno is widely recommended for beginners due to its ease of use, vast online resources, and large community support. It simplifies programming and hardware interfacing, making it suitable for foundational projects like line followers or obstacle avoiders.
How much does it typically cost to build a DIY robot?
Costs vary significantly depending on the project's complexity and component choices. Simple projects can range from $50 to $150, while intermediate builds might cost $200 to $500. Advanced robots, especially those involving single-board computers, multiple high-torque servos, or specialized sensors, can easily exceed $1000.
What programming languages are commonly used for DIY robots?
For microcontrollers like Arduino, C++ (with Arduino IDE) is the primary language. For projects involving single-board computers (e.g., Raspberry Pi), Python is very popular due to its readability, extensive libraries for robotics, and integration with computer vision tools like OpenCV.
Where can I find reliable resources and tutorials for robot projects?
Numerous online platforms offer tutorials, forums, and project guides. Websites like Instructables, Hackaday, and YouTube channels dedicated to electronics and robotics are excellent starting points. Many component manufacturers also provide detailed documentation and sample code for their products.